Tyler Lum
Building robots with human-level dexterity
Hi, my name is Tyler Lum and I am a 5th-year Computer Science PhD student at Stanford University studying artificial intelligence and robotics. I am advised by Professor C. Karen Liu in The Movement Lab (TML) and Professor Jeannette Bohg in the Interactive Perception and Robot Learning (IPRL) Lab, and I am supported by an NSERC Postgraduate Scholarship (PGS-D).
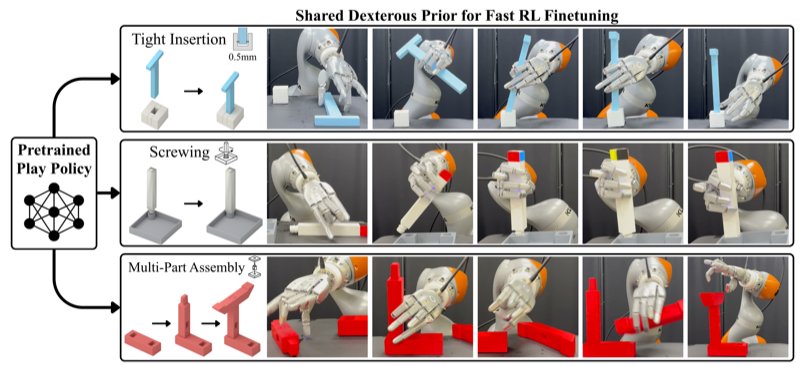
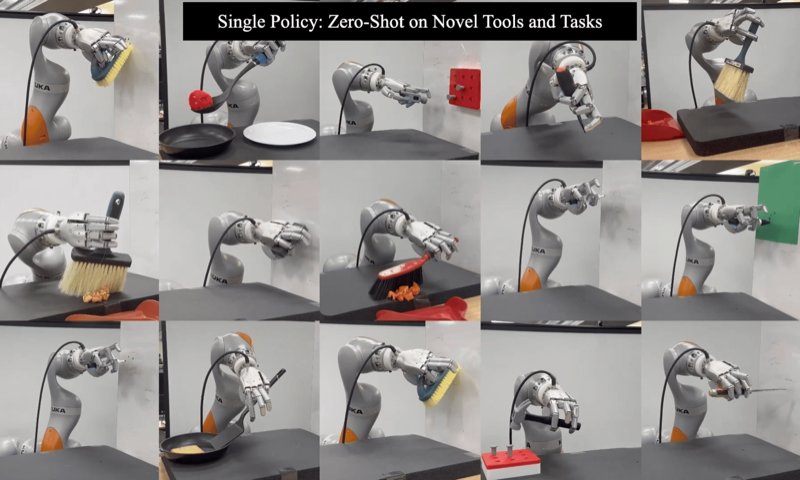
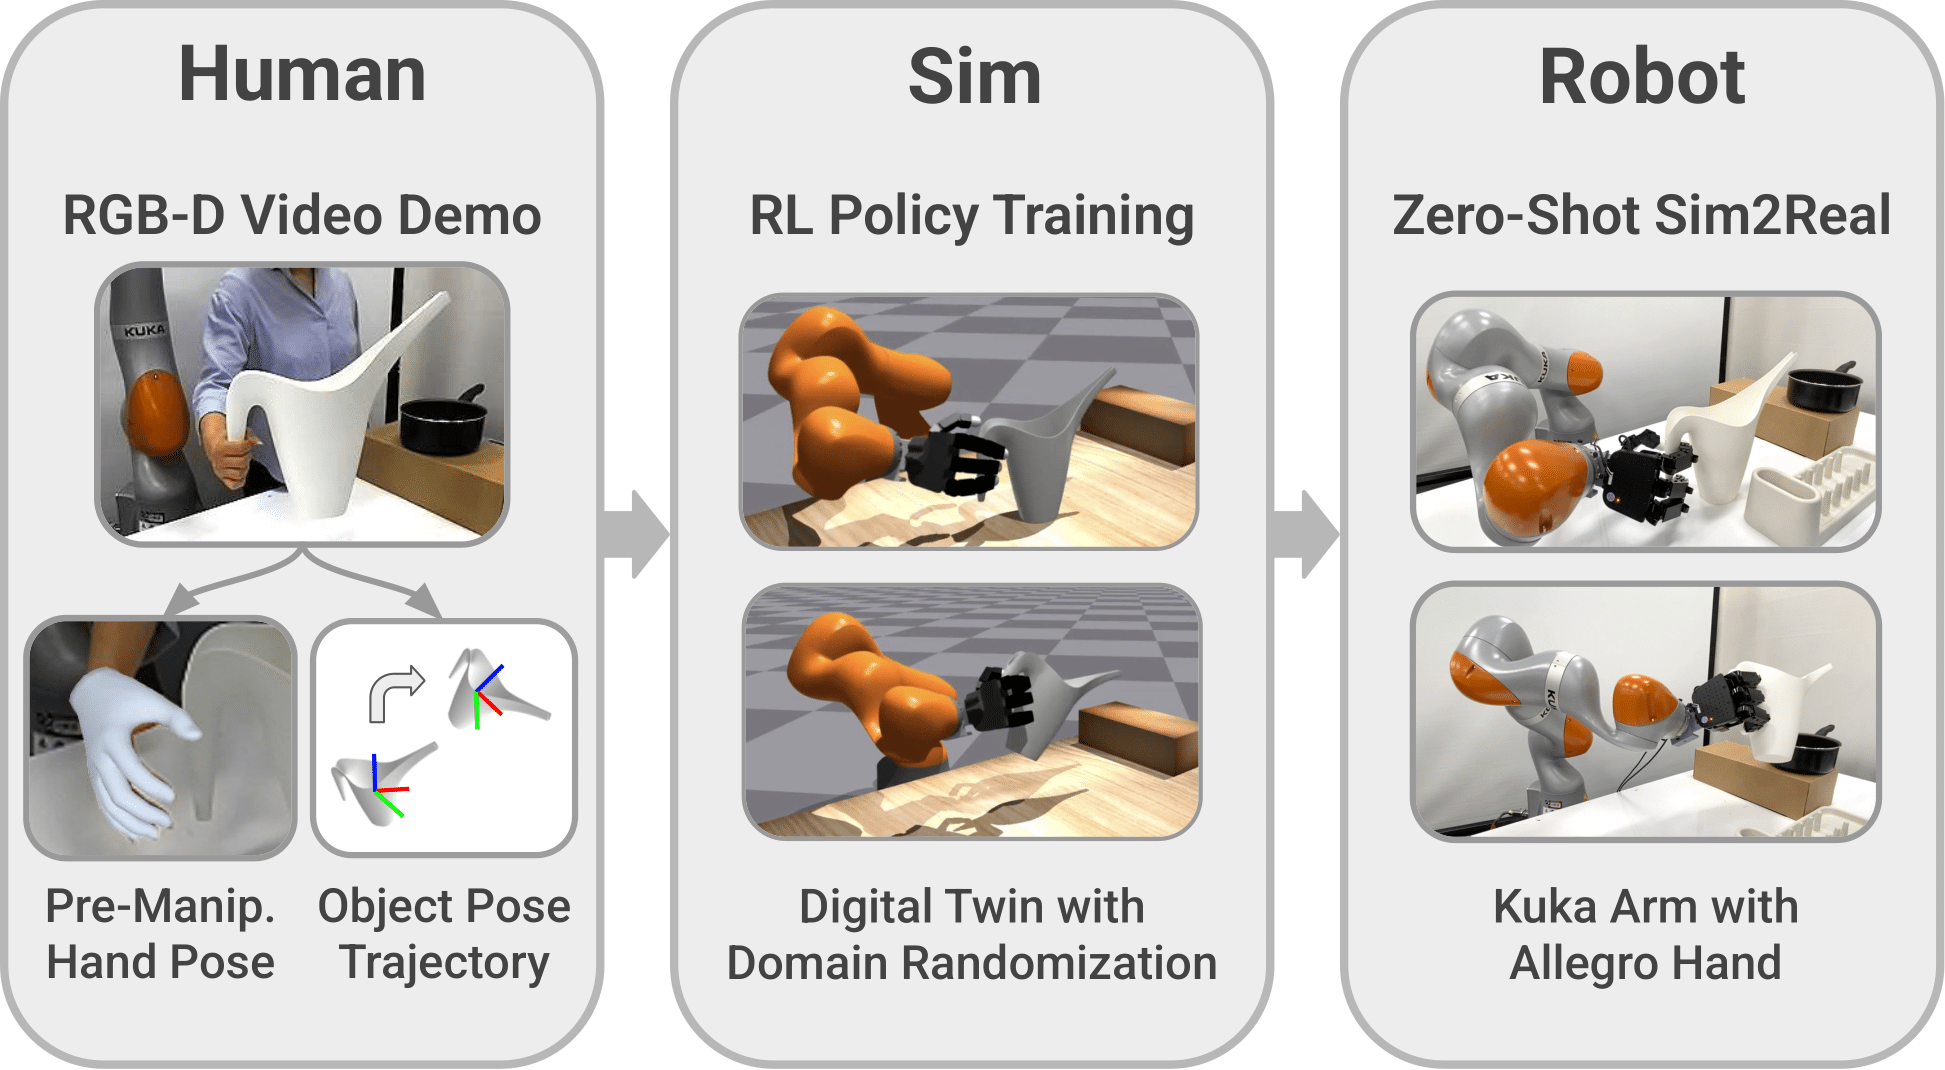
My goal is to build general-purpose dexterity for real-world robots: reusable low-level physical skills that generalize across new objects and tasks. Most dexterous manipulation today is either highly dexterous but narrow (often a single object and a single task) or broad but limited to slow pick-and-place. My research asks how far simulation, reinforcement learning, and human videos can take us toward both high dexterity and broad generality. Simulation is the only source of detailed contact-rich interaction data that scales with compute rather than human effort, but it has no semantics and no sense of which tasks matter or how a person would approach them. Human videos are the opposite: abundant and rich in semantics and strategy, but missing the actions, forces, and contact that dexterity actually runs on. I am very excited about research that brings these two data sources together, toward robots that can do any physical task that humans can do.
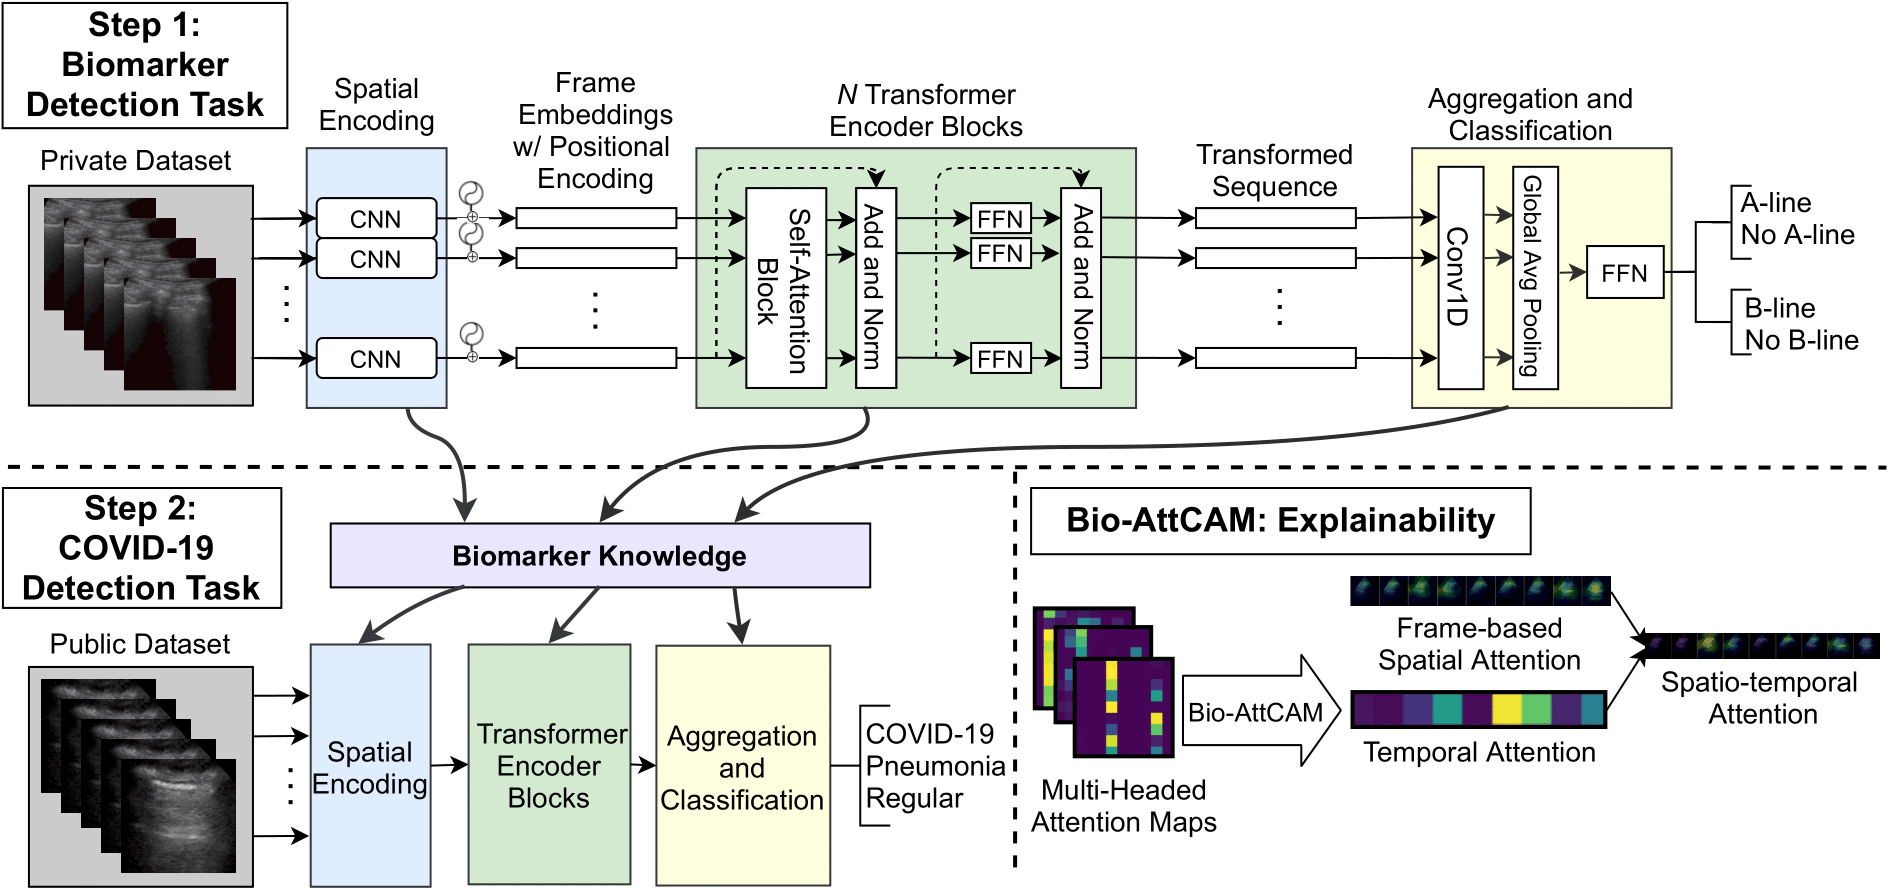
Before my PhD, I studied Engineering Physics at the University of British Columbia (UBC), where I graduated as a Wesbrook scholar - one of UBC's most prestigious designations given to the top 20 overall senior students. I was advised by Professor Michiel van de Panne studying reinforcement learning and motion planning for quadruped robots. I also worked with Professor Purang Abolmaesumi on deep learning for medical image analysis.